The system behind the ambition.
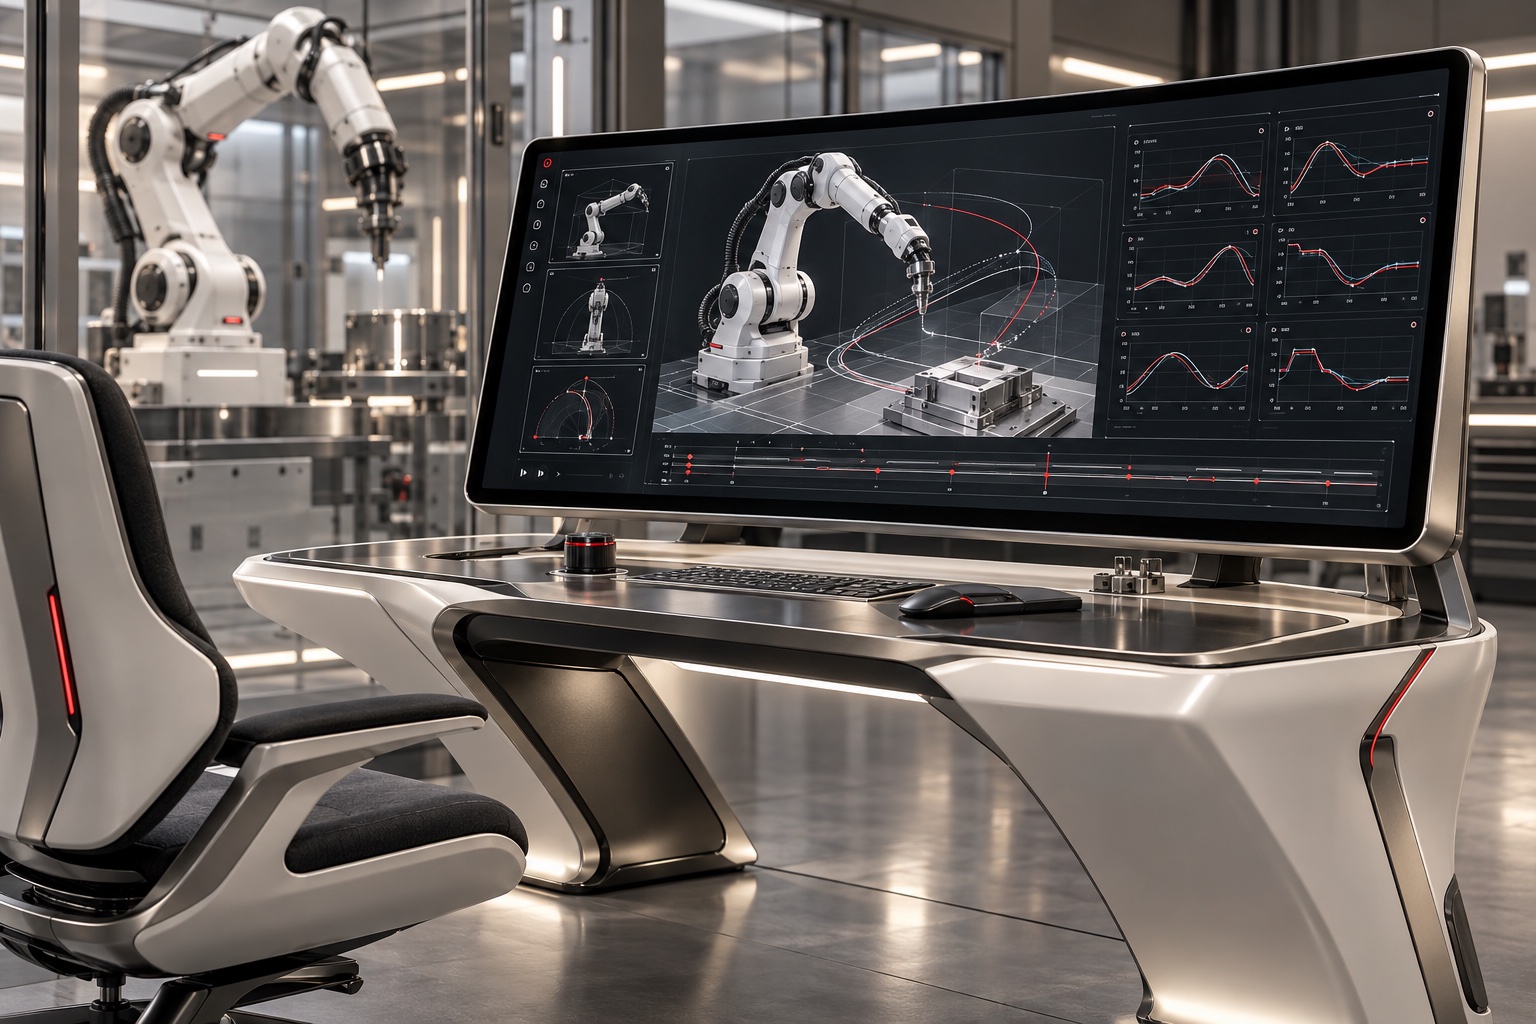
The runtime takes a path and a supervisor's command and turns them into local motion the drives can execute.
A trajectory becomes real through coordinated control of the machine's axes. Timing, limits, feedback, supervision, and recovery must remain connected to the physical system. The runtime defines how a requested movement is executed and how the machine responds when that movement cannot continue.
Engineering scope, interfaces and validation are established for each engagement.
Built around the mission.
Local control
Time-critical functions follow the machine.
Faults
Limits, sensor faults, and a lost link have a defined response.
Integration
The same interfaces serve the component and the machine.
From requirements to validation.
- DefineEnvironment, interfaces and operating responsibilities.
- IntegrateThe hardware, software and supporting infrastructure.
- ValidateAgreed criteria, fault response and recovery.